


Table of Contents
Most buyers spend considerable time selecting the right robot arm and laser source for their robotic welding workstation. Far fewer give the same attention to the positioner — the component that holds, orients, and rotates the workpiece during welding. This is a mistake. The positioner configuration is one of the most direct determinants of weld quality, production efficiency, and the range of parts your workstation can handle. Choose the wrong positioner and you'll be fighting your own equipment every production cycle. Choose the right one and the robot can access every weld joint in the optimal position, every time.
This guide covers every major welding positioner type used in robotic laser welding workstations — what each type is, how it works, what it's best suited for, and the specific scenarios where each configuration delivers the most value. By the end, you'll have a clear framework for matching positioner type to your parts, production volume, and automation requirements.
Why the Positioner Is the Unsung Hero of Robotic Welding
In manual welding, an experienced welder naturally adjusts their body position, torch angle, and travel direction to access weld joints from the most favorable angle. They rotate the part by hand, tilt it on a bench, or reposition themselves around the workpiece. This physical adaptability is one of the things skilled manual welders do instinctively — and one of the things robotic welding systems must replicate mechanically.
A 6-axis collaborative robot has significant reach and articulation capability. But even a 6-axis robot has limits: it cannot always reach the underside of a part, access a tight internal corner, or maintain the optimal torch angle on a complex curved surface without the workpiece being positioned cooperatively.
This is what the positioner does. It extends the effective working envelope of the robot by repositioning the workpiece — rotating it, tilting it, or indexing it between weld sequences — so that every required weld joint is presented to the robot in the most accessible, most favorable orientation.
The result is:
Better weld quality — welds made in the flat or horizontal position consistently outperform welds made in vertical or overhead positions, even for robotic systems
Simpler robot programming — fewer complex path sequences when the workpiece is correctly oriented
Faster cycle times — less robot repositioning between weld sequences
Access to joints that would otherwise be unreachable — without the positioner, some joints simply cannot be welded robotically
More consistent fixturing — positioners provide a repeatable, stable mounting point for workpiece fixtures
The Four Primary Positioner Types
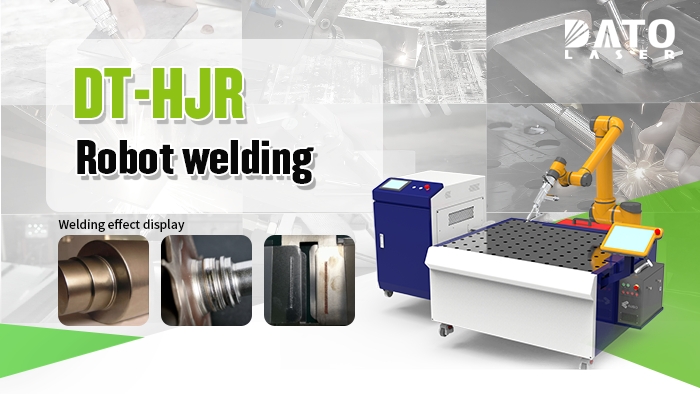
DATO robotic laser welding workstations are configured with four primary positioner types, each suited to a different range of part geometries and production requirements. Understanding the mechanical principle behind each type is the foundation for making the right selection.
Type 1: Flat Welding Platform (Fixed Table)
What It Is
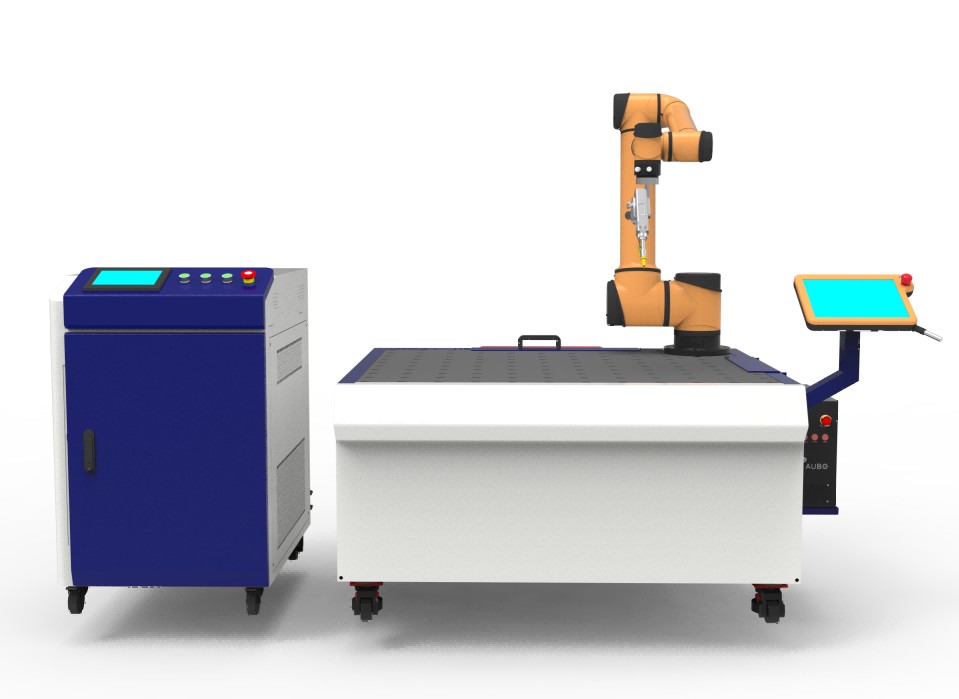
The flat welding platform is the simplest positioner configuration — a fixed, flat work surface on which the workpiece is fixtured in a single orientation. There is no powered rotation or tilting; the workpiece remains stationary throughout the welding cycle. The robot moves around the fixed workpiece to access all required weld joints.
The platform surface is typically steel with a grid of mounting holes or T-slots that allow fixtures to be bolted down in any configuration. Some platforms include integrated clamping systems for faster workpiece loading and unloading.
How It Works in Practice
The operator loads the workpiece onto the platform, secures it in the fixture, and initiates the welding program. The robot executes all programmed weld paths with the workpiece in a fixed position. When the welding cycle is complete, the operator unloads the finished part and loads the next workpiece.
For parts with welds accessible from above and the sides — flat panels, brackets, enclosures, frames — the flat platform is entirely sufficient. The robot's 6-axis articulation can access most joints on a flat part without any workpiece rotation.
Best Applications
Flat sheet metal components: panels, covers, lids, base plates
Enclosures and cabinets: where all welds are on the exterior surfaces
Brackets and frames: with welds on accessible faces
Simple structural components: where joint access does not require workpiece rotation
High-mix, low-volume production: where fixture changeover speed is more important than cycle time optimization
Key Advantages
Lowest cost — no powered rotation mechanism, simplest mechanical design
Simplest programming — fixed workpiece position means straightforward path programming
Fastest fixture changeover — no positioner alignment required between part types
Unlimited workpiece size (within robot reach) — no rotational envelope constraint
Easiest maintenance — no rotating components to service
Limitations
No access to underside welds — joints on the bottom face of the workpiece cannot be reached without manual repositioning
Suboptimal weld position for some joints — vertical and overhead welds are less favorable than flat/horizontal welds
Manual repositioning required for complex parts — if the part needs to be flipped or rotated mid-cycle, the operator must intervene
When to Choose the Flat Platform
Choose the flat welding platform when your parts have all required weld joints accessible from above and the sides, when production mix is high and fixture changeover speed matters, or when budget is a primary constraint and the part geometry does not require workpiece rotation.
The flat platform was the positioner configuration used in DATO's Greek sheet metal fabricator deployment — where the customer's parts (sheet metal components, brackets, and enclosures) had all weld joints accessible from above and the sides, making powered rotation unnecessary.
Type 2: Single-Axis Rotary Positioner (Welding Turntable)
What It Is
The single-axis rotary positioner — also called a welding turntable or single-axis headstock — rotates the workpiece around a single axis (typically vertical or horizontal) under servo motor control. The robot and positioner work in coordinated motion: as the positioner rotates the workpiece, the robot adjusts its position to maintain the correct torch angle and travel speed along the weld path.
In a robotic welding system, the positioner's rotation axis is treated as an additional programmed axis — the robot controller coordinates positioner rotation with robot arm movement to execute complex weld paths that would be impossible with the workpiece fixed.
How It Works in Practice
For a cylindrical part — a pipe assembly, a round tank, a circular flange — the positioner rotates the part continuously while the robot holds the welding head at a fixed position relative to the top of the part. The result is a perfectly consistent circumferential weld, executed at constant speed and torch angle, without the robot needing to move around the part.
For non-cylindrical parts with welds on multiple faces, the positioner indexes between positions — rotating the part to present each face to the robot in turn. The robot welds one face, the positioner rotates to the next face, the robot welds again.
Best Applications
Cylindrical parts: pipes, tubes, round tanks, pressure vessels, circular flanges
Pipe assemblies: straight pipe sections, pipe-to-flange joints, pipe-to-fitting joints
Rotational components: shafts, hubs, rings, circular brackets
Parts with welds on multiple faces: where indexing between faces is sufficient (no tilting required)
High-volume pipe and tube welding: where circumferential weld consistency is the primary quality requirement
Key Advantages
Ideal for circumferential welds — continuous rotation produces perfectly consistent circular welds
Eliminates positional weld quality variation — the weld is always made in the flat/horizontal position as the part rotates
Enables full circumferential access — the robot can weld the entire circumference of a cylindrical part from a single fixed position
Simple coordination programming — single-axis coordination is straightforward to program and verify
Compact footprint — single-axis positioners are relatively compact compared to multi-axis configurations
Limitations
No tilting capability — cannot present angled or inclined weld joints in the optimal position
Limited for complex 3D geometries — parts with welds on multiple non-parallel faces may require multiple index positions or manual repositioning
Fixture design complexity for non-cylindrical parts — securing irregular parts on a rotary positioner requires more complex fixture design
When to Choose the Single-Axis Rotary Positioner
Choose the single-axis rotary positioner when your primary production involves cylindrical parts, pipe assemblies, or other rotational components where circumferential weld consistency is the key quality requirement.
The single-axis rotary positioner was one of the configurations in DATO's Romanian customer deployment — used specifically for the round pipe welding portion of their production, while a flat platform handled the structural component welding.

Type 3: Dual-Axis P-Type Positioner (Tilt-and-Rotate)
What It Is
The dual-axis P-type positioner provides rotation around two independent axes — a primary rotation axis and a secondary tilt axis — giving the workpiece the ability to be both rotated and tilted to any orientation within its mechanical range. The "P-type" designation refers to the characteristic shape of the positioner frame, which resembles the letter P when viewed from the side.
This two-axis capability means the workpiece can be presented to the robot at virtually any angle — flat, tilted, inverted, or at any intermediate position — allowing the robot to access weld joints that would be unreachable with a single-axis or fixed positioner.
In coordinated robotic welding, both positioner axes are treated as programmed axes synchronized with the robot arm — enabling complex, multi-plane weld paths to be executed with the workpiece continuously repositioning to maintain the optimal weld position.
How It Works in Practice
Consider a complex fabricated assembly — a machinery bracket with welds on the top face, both side faces, and the underside. With a flat platform, the underside welds are inaccessible. With a single-axis rotary positioner, the part can be rotated to present the sides, but tilting to access the underside requires a second axis.
With the dual-axis P-type positioner, the part is first welded on the top face with the positioner in the flat position. The tilt axis then rotates the part 90° to present the side face. After welding the side, the tilt axis continues to rotate the part to present the underside — now accessible from above in the flat welding position. All of this happens under programmed control, without the operator touching the part between weld sequences.
Best Applications
Complex 3D fabricated assemblies: machinery frames, structural brackets, equipment housings
Parts with welds on multiple non-parallel faces: top, sides, and underside all requiring welding
Mixed production with varied part geometries: where a single positioner must accommodate multiple different part types
Precision assemblies: where maintaining flat weld position across all joints is critical for quality
Batch production with frequent changeover: where the positioner's versatility reduces the need for multiple dedicated fixtures
Key Advantages
Maximum weld joint accessibility — two-axis capability allows access to virtually any weld joint orientation
Flat welding position for all joints — tilting the part means every weld can be made in the flat position, regardless of joint orientation on the part
Most versatile positioner type — handles the widest range of part geometries
Enables complex multi-face welding sequences — without manual repositioning
Ideal for mixed production — one positioner handles multiple different part types
Gravity-assisted weld pool control — tilting the part to the optimal angle improves weld pool behavior and reduces defect risk
Limitations
Higher cost — two servo axes, more complex mechanical design
Larger footprint — the P-type frame requires more floor space than a single-axis positioner
More complex programming — two-axis coordination requires more careful path planning
Payload and size constraints — the positioner's tilt axis has a maximum moment load that limits the size and weight of parts that can be tilted
When to Choose the Dual-Axis P-Type Positioner
Choose the dual-axis P-type positioner when your parts have welds on multiple faces requiring different orientations, when you produce a variety of different part types on a single workstation, or when weld quality on all joint faces is a primary requirement.
The dual-axis P-type positioner was the configuration used in DATO's Swiss customer deployment — where the manufacturer needed to weld multiple different workpiece types in batch production, and the positioner's versatility was the key enabler of efficient changeover between part types. It was also one of the positioner configurations in the Romanian deployment, used alongside a single-axis positioner for a mixed pipe-and-structural production requirement.
Type 4: Headstock-Tailstock Positioner (Between-Centers)
What It Is
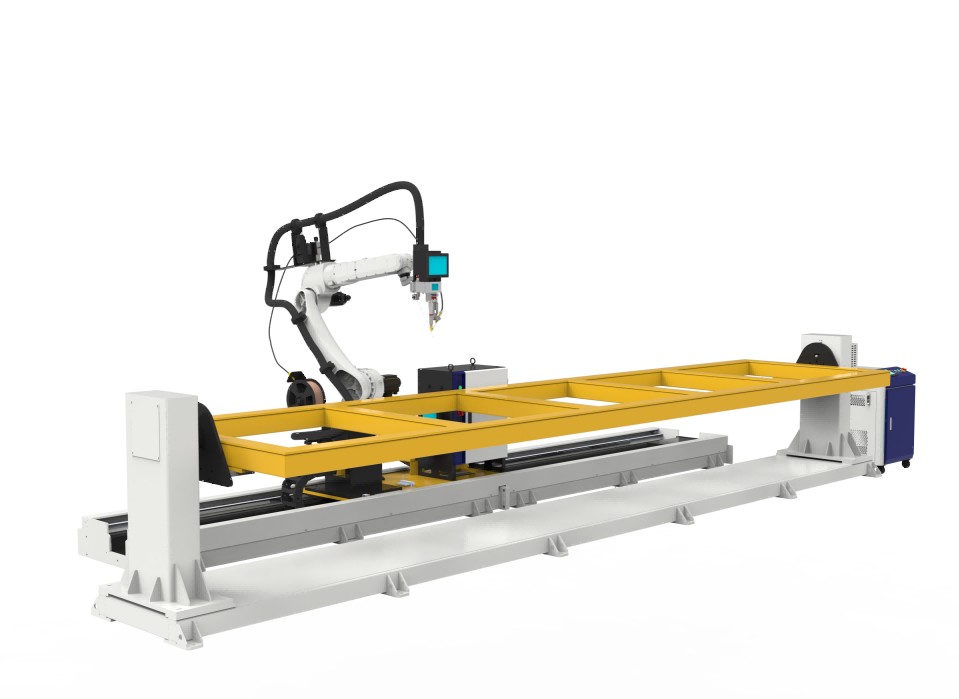
The headstock-tailstock positioner supports the workpiece between two driven chucks — a powered headstock on one end and a supported tailstock on the other — and rotates the part along its length axis. This configuration is specifically designed for long, elongated parts that cannot be cantilevered on a rotary table without excessive deflection or vibration.
The headstock provides the drive torque and positional control. The tailstock provides support at the opposite end of the part, maintaining alignment and preventing deflection under the workpiece's own weight and the welding forces. Both headstock and tailstock are typically adjustable along a linear rail to accommodate different part lengths.
How It Works in Practice
A long structural beam, tube assembly, or shaft is loaded between the headstock and tailstock chucks. The chucks are tightened to secure the part, and the headstock drive rotates the part along its length axis while the robot welds along the length of the part or around circumferential joints.
For longitudinal welds — welds running along the length of a tube or beam — the positioner holds the part at the optimal rotational angle while the robot travels along the weld path. For circumferential welds — joints around the circumference of a tube — the positioner rotates the part while the robot holds position.
Best Applications
Long structural beams and columns: I-beams, box sections, rectangular hollow sections
Long tube and pipe assemblies: multi-meter pipe sections, tube frames, structural tubes
Shafts and axles: requiring circumferential or longitudinal welds along their length
Ladder and frame structures: where the frame members are long and require welding along their length
Agricultural and construction equipment components: long structural members with multiple weld joints
Key Advantages
Essential for long parts — the only positioner type that provides stable support for parts too long to cantilever
Prevents deflection and vibration — between-centers support maintains part alignment throughout the welding cycle
Enables full-length access — the robot can weld along the entire length of the part without repositioning
Consistent rotational positioning — servo-controlled rotation provides precise angular positioning for longitudinal welds
Handles heavy parts — the distributed support of headstock and tailstock allows heavier parts than a cantilevered rotary table
Limitations
Largest footprint — the headstock-tailstock configuration requires significant floor space along the part length axis
Limited to elongated parts — not suitable for compact, blocky, or complex 3D assemblies
Loading and unloading complexity — securing parts between chucks takes more time than placing a part on a flat platform
Higher cost — two driven units plus linear rail infrastructure
When to Choose the Headstock-Tailstock Positioner
Choose the headstock-tailstock positioner when your primary production involves long structural members, tube assemblies, or shafts where the part length makes cantilevered support impractical. If your longest regular production parts exceed approximately 800–1000mm in length and require welding along their length, this configuration is likely the right choice.
Side-by-Side Comparison: All Four Positioner Types
Factor | Flat Platform | Single-Axis Rotary | Dual-Axis P-Type | Headstock-Tailstock |
Axes of motion | 0 (fixed) | 1 (rotation) | 2 (rotation + tilt) | 1 (rotation along length) |
Best part geometry | Flat, accessible joints | Cylindrical, multi-face | Complex 3D, multi-face | Long beams, tubes, shafts |
Underside weld access | No | No | Yes | Yes (by rotation) |
Circumferential welds | No | Yes — ideal | Yes | Yes |
Longitudinal welds | Limited | Limited | Limited | Yes — ideal |
Mixed part types | Good | Moderate | Excellent | Poor |
Programming complexity | Low | Low-moderate | Moderate-high | Moderate |
Footprint | Small | Small-medium | Medium | Large |
Cost | Lowest | Low-moderate | Moderate-high | Moderate-high |
Payload/size limit | Robot reach only | Rotary table capacity | Tilt axis moment limit | Chuck capacity + rail length |
Typical applications | Sheet metal, enclosures | Pipes, tanks, flanges | Machinery, mixed batch | Beams, long tubes, frames |

Multi-Positioner Configurations: When One Is Not Enough
For manufacturers with genuinely diverse production requirements — multiple product lines with fundamentally different part geometries — a single positioner type may not be the right answer. DATO workstations can be configured with multiple positioners on a single workstation, allowing the robot to work with different positioner configurations for different part types without requiring a separate workstation for each.
The most common multi-positioner configuration is the flat platform + single-axis rotary combination — providing flat-table capability for sheet metal and structural parts alongside rotary capability for pipe and cylindrical components. This was the configuration used in DATO's Romanian customer deployment, where the manufacturer needed to weld both round pipes (single-axis rotary) and flat structural components (welding platform) on a single workstation.
Other common multi-positioner combinations include:
Dual-axis P-type + flat platform — for manufacturers whose production is primarily complex 3D assemblies but includes some simple flat parts
Single-axis rotary + headstock-tailstock — for pipe fabricators who produce both short pipe assemblies and long tube structures
Two flat platforms (twin-station) — for high-volume production where one platform is being loaded/unloaded while the robot welds on the other, maximizing robot utilization
The Twin-Station Configuration: Maximizing Robot Utilization
The twin-station (or dual-table) configuration deserves special mention because it addresses a fundamental efficiency challenge in robotic welding: robot idle time during workpiece loading and unloading.
In a single-station configuration, the robot must wait while the operator unloads the finished part and loads the next workpiece. Depending on part complexity and fixture design, this loading/unloading time can represent 20–40% of the total cycle time — meaning the robot is idle for a significant portion of every production cycle.
The twin-station configuration eliminates this idle time by providing two identical work positions. While the robot welds on Station A, the operator loads and unloads Station B. When the robot finishes on Station A, it immediately moves to Station B — which is already loaded and ready — while the operator works on Station A. The robot is almost never waiting for the operator.
For high-volume production of a single part type, the twin-station configuration can increase effective robot utilization from 60–70% to 85–95%, delivering a proportional increase in production output without any increase in robot speed or welding parameters.
How to Select the Right Positioner: A Practical Decision Framework
Work through these five questions to identify the right positioner configuration for your production:
Step 1: What is the geometry of your primary production part?
Part Geometry | Starting Recommendation |
Flat panels, sheet metal, enclosures | Flat platform |
Cylindrical parts, pipes, round tanks | Single-axis rotary |
Complex 3D assemblies, multi-face welds | Dual-axis P-type |
Long beams, tubes, shafts (>800mm) | Headstock-tailstock |
Mixed — multiple different geometries | Dual-axis P-type or multi-positioner |
Step 2: Do you need to weld the underside of any parts?
If yes → Dual-axis P-type is required (or manual repositioning, which defeats the purpose of automation).
If no → flat platform or single-axis rotary may be sufficient.
Step 3: What is the longest dimension of your largest regular production part?
Under 500mm → Any positioner type is viable; choose based on geometry
500mm–1000mm → Single-axis rotary or dual-axis P-type; check tilt axis moment capacity for P-type
Over 1000mm → Headstock-tailstock strongly recommended; verify robot reach covers the full part length
Step 4: How many different part types will this workstation produce?
1–2 part types → Optimize positioner for those specific geometries
3–5 part types → Dual-axis P-type for maximum versatility, or multi-positioner configuration
5+ part types (high-mix) → Dual-axis P-type + flat platform combination; evaluate twin-station for volume
Step 5: What is your production volume and cycle time requirement?
Low volume, high mix → Prioritize changeover speed → flat platform or dual-axis P-type
High volume, single part type → Prioritize cycle time → twin-station configuration
High volume, cylindrical parts → Single-axis rotary with continuous rotation welding
Positioner and Fixture: Why They Must Be Designed Together
A critical point that is often overlooked in workstation planning: the positioner and the workpiece fixture must be designed as a system, not as separate components.
The positioner provides the mechanical capability to rotate and tilt the workpiece. The fixture translates that capability into precise, repeatable workpiece positioning for the robot's programmed paths. A high-quality positioner with a poorly designed fixture will not deliver consistent weld quality. A well-designed fixture on the right positioner will.
Key fixture design principles for each positioner type:
Flat platform fixtures:
Locate the workpiece against positive stops in X, Y, and Z
Use quick-release clamps for fast loading/unloading
Design for single-handed loading where possible
Ensure all weld joints are accessible without the fixture blocking robot approach angles
Single-axis rotary fixtures:
Balance the workpiece mass around the rotation axis to minimize motor load and vibration
Ensure the fixture does not interfere with the robot at any rotational position
Design for the full 360° rotation range — check clearances at all positions
Use self-centering chucks or precision-located mounting faces for cylindrical parts
Dual-axis P-type fixtures:
Calculate the moment load at the tilt axis for the combined workpiece + fixture mass
Ensure the fixture does not exceed the positioner's rated moment capacity at any tilt angle
Design for the full tilt range — check clearances between fixture, workpiece, and positioner frame at all positions
Consider the workpiece center of gravity when designing for inverted or extreme tilt positions
Headstock-tailstock fixtures:
Design chuck faces for positive location — avoid relying on friction alone for angular positioning
Ensure the tailstock support does not interfere with weld joint access along the part length
Design for consistent part-to-part loading alignment — small angular errors at the chuck face become significant positional errors at the far end of a long part
Real Deployment Examples: Positioner Selection in Practice
Romania — Multi-Positioner Configuration for Mixed Production
Parts: Round pipes (stainless steel) + flat structural componentsPositioner configuration: Single-axis rotary positioner + flat welding platform + dual-axis P-type positionerRobot: Aubo i10 6-axis cobotLaser: 2000W fiber laser
The Romanian manufacturer's production required welding two fundamentally different part types: round pipes requiring circumferential welds, and flat structural components requiring accessible-face welds. Rather than purchasing two separate workstations, DATO configured a single workstation with both a single-axis rotary positioner and a flat welding platform — allowing the robot to work with either positioner depending on the production schedule. The dual-axis P-type was added for a third part type requiring multi-face access.
Key insight: Multi-positioner configurations can deliver the flexibility of multiple workstations at significantly lower total cost.
Switzerland — Dual-Axis P-Type for Batch Multi-Part Production
Parts: Multiple different workpiece types, batch productionPositioner configuration: Dual-axis P-type positionerRobot: Aubo i10 6-axis cobot (2000W laser)
The Swiss manufacturer's primary challenge was efficiently welding multiple different workpiece types in batch production — with frequent changeover between part types. The dual-axis P-type positioner's ability to handle different part geometries without requiring a positioner change made it the right choice. Each part type had its own stored program and fixture configuration, allowing changeover to be completed by the operator in minutes.
Key insight: For mixed-production manufacturers, the dual-axis P-type positioner's versatility often delivers better ROI than a more specialized positioner optimized for a single part type.
Greece — Flat Platform for Sheet Metal Batch Production
Parts: Sheet metal components, brackets, enclosuresPositioner configuration: Flat welding platformRobot: Aubo i10 6-axis cobot (1500W laser)
The Greek sheet metal fabricator's parts were standard sheet metal components with all weld joints accessible from above and the sides. The flat welding platform was the right choice — simple, fast to load, and entirely sufficient for the part geometry. Adding a powered positioner would have added cost and complexity without delivering any production benefit for these specific parts.
Key insight: The right positioner is the one that fits your parts — not the most sophisticated one available.
DATO's Positioner Configuration Approach
At DATO, positioner selection is part of our standard workstation configuration process — not an afterthought. Before recommending a positioner type, our engineering team reviews:
Your part drawings or samples — to understand geometry, weld joint locations, and access requirements
Your production volume and mix — to determine whether a single positioner type or multi-positioner configuration is more appropriate
Your workpiece weight and dimensions — to verify positioner payload and moment capacity
Your operator profile — to assess programming complexity requirements
Your floor space constraints — to ensure the positioner configuration fits your workshop layout
The output is a specific positioner recommendation with fixture design guidance — not a generic "choose from our catalog" response.
Related reading:
What Is a Robotic Welding Workstation? Open vs Enclosed Types Explained
Industrial Robot Laser Welding vs Collaborative Robot Welding: Which Is Right for Your Factory?
Aubo vs Elite Cobot for Laser Welding: Which Brand Should You Choose?
Frequently Asked Questions
Q1: Do I need a positioner for robotic laser welding, or can the robot handle everything?
For simple flat parts with all weld joints accessible from above and the sides, a flat welding platform (which is technically a positioner with zero axes of motion) is sufficient. For parts with welds on multiple faces, cylindrical parts requiring circumferential welds, or long structural members, a powered positioner is essential for achieving consistent weld quality and practical cycle times. The robot's 6-axis articulation is powerful, but it cannot substitute for a positioner when the workpiece geometry requires it.
Q2: What is the maximum workpiece weight a positioner can handle?
This depends on the specific positioner model and configuration. Single-axis rotary positioners in DATO workstation configurations typically handle workpieces up to 200–500kg depending on the model. Dual-axis P-type positioners have both a payload rating and a moment load rating — the moment load (weight × distance from tilt axis) is often the binding constraint for large parts. Headstock-tailstock configurations can handle heavier parts because the weight is distributed between two support points. Provide your workpiece weight and dimensions to DATO's engineering team for a specific capacity assessment.
Q3: Can the positioner and robot move simultaneously (coordinated motion)?
Yes — in DATO robotic welding workstations, the positioner axes are integrated with the robot controller as additional programmed axes. This means the positioner can rotate or tilt the workpiece continuously while the robot moves along the weld path, enabling complex coordinated welding sequences. Coordinated motion is particularly important for circumferential welds on cylindrical parts, where the positioner rotates the part while the robot holds a fixed position.
Q4: How long does it take to change fixtures between different part types?
Fixture changeover time depends on the fixture design and the positioner type. On a flat welding platform with well-designed quick-release fixtures, changeover can be completed in 2–5 minutes. On a dual-axis P-type positioner with multiple stored programs, the robot program changeover is near-instant — the physical fixture change takes 5–15 minutes depending on complexity. DATO designs fixtures with changeover speed as an explicit requirement for mixed-production workstations.
Q5: Is the dual-axis P-type positioner always better than the single-axis rotary?
Not always — the right positioner is the one that fits your parts. For cylindrical parts requiring circumferential welds, the single-axis rotary positioner is simpler, cheaper, and entirely sufficient. The dual-axis P-type's additional tilt capability adds cost and programming complexity that is only justified when your parts actually require tilting. Choosing the dual-axis P-type for a production that only needs single-axis rotation is an unnecessary investment.
Q6: Can I add a positioner to an existing DATO workstation later?
Yes, in principle — but it is more cost-effective to specify the positioner at the time of initial purchase. Adding a positioner to an existing workstation requires mechanical integration, controller reconfiguration, and re-programming of existing welding paths to account for the new positioner axes. These integration costs can approach or exceed the cost of the positioner itself. If you anticipate needing a positioner in the future, specify it at purchase even if you don't use all its capability immediately.
Q7: What is the difference between a positioner and a fixture?
The positioner is the powered mechanical device that rotates, tilts, or indexes the workpiece — it provides the motion. The fixture is the custom-designed tooling that holds the specific workpiece in the correct position on the positioner — it provides the location. Every workstation needs both: the positioner provides the capability, and the fixture translates that capability into precise, repeatable workpiece positioning for the robot's programmed paths.
Q8: How do I know if my parts need a dual-axis positioner or if a single-axis is sufficient?
The key question is: do any of your required weld joints face downward (toward the floor) when the part is in its natural resting position? If yes, you need either a dual-axis positioner to tilt the part and bring those joints to an accessible position, or you need to accept that those joints will be welded in a less favorable position. For most structural and fabricated parts, if you can answer "all my welds are on the top and sides of the part," a single-axis or flat platform is sufficient.
Ready to configure the right positioner for your robotic welding workstation?
Explore the DATO DT-HJR Robotic Laser Welding Machine Request a Free Workstation and Positioner Configuration Consultation Send Your Part Drawings for a Free Positioner Recommendation View All DATO Laser Welding Solutions
Shandong Dato Machinery Co., Ltd. — Laser Industry Leader Since 2007 info@datolaser.com | WhatsApp: +86-19353173156 | www.datolaser.com
Related Blogs
-
 In 2026, sheet metal fabricators are under increasing pressure to produce faster, maintain better quality, control labor costs, and respond more efficiently to custom orders. As competition continues to grow in both domestic and global markets, manufacturers are looking for practical ways to improveBuyer's Guide
-
 For many manufacturers, the biggest equipment decisions are not only about what to buy, but also when to buy. In 2026, September stands out as one of the most practical and strategic months for factories to upgrade production equipment, improve automation capability, and prepare for future growth.WhBuyer's Guide
-
 Choosing the right equipment is one of the most important decisions a manufacturer can make in 2026. Whether your factory is upgrading a welding line, expanding sheet metal fabrication capacity, or planning a broader automation project, selecting the correct machine affects production efficiency, prBuyer's Guide
-
 In 2026, more fabricators are investing in CNC press brakes, sheet metal bending machines, and other metal fabrication equipment to improve accuracy, increase output, and build more efficient production lines.During the September Sourcing Sale 2026, DATO LASER gives manufacturers and sheet metal worBlog
